Sitemap
A list of all the posts and pages found on the site. For you robots out there is an XML version available for digesting as well.
Pages
About Me
Archive Layout with Content
Posts by Category
Posts by Collection
Experience
Markdown
Page not in menu
Page Archive
Selected Projects
Publications & Reports
Robot Learning — Imitation Learning on the SO-101 Arm
Sitemap
Posts by Tags
Talk map
Talks and presentations
Teaching
Terms and Privacy Policy
Blog posts
Jupyter notebook markdown generator
Posts
Future Blog Post
Published:
This post will show up by default. To disable scheduling of future posts, edit config.yml and set future: false.
Blog Post number 4
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 3
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 2
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Blog Post number 1
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
experiences
REAL Lab — Mila / Université de Montréal
Designed a transformer-based actor-critic architecture with a novel tokenization scheme to train a single reinforcement-learning policy across multiple robot morphologies simultaneously. Conditioned the policy on BERT-encoded URDF (robot-structure) descriptions, enabling generalization to robot embodiments unseen during training, without per-robot retraining.
Wipro Ltd.
Optimized a semantic-segmentation model for real-time scene understanding on an autonomous-vehicle platform, targeting the NVIDIA Jetson ORIN edge device. Converted the PyTorch model to an INT8-quantized TensorRT engine (calibrated on ~6,000 images), achieving a 3× inference speedup (from ~50 to ~150 fps) while maintaining an acceptable accuracy threshold.
Indian Institute of Science (IISc)
Developed and implemented an actor-critic algorithm to solve constrained optimization for cooperative multi-agent reinforcement learning. Evaluated the approach on two benchmark multi-agent environments — Cooperative Navigation and Cooperative Treasure Collection — using an Azure cloud virtual machine. This work led to a publication at AAMAS 2021.
Mindtree Ltd.
Implemented research papers for customer-specific use cases across reinforcement learning, NLP and computer vision. Selected projects include Explainable Product Recommendation, Airline Seat Inventory and Dynamic Pricing, and Fine-Grained Visual Classification.
portfolio
Imitation Learning on a Physical Robotic Arm (SO-101)
Deployment of imitation-learning policies (ACT, SmolVLA, π0.5) on a SO-101 robotic arm: collected teleoperated demonstrations and fine-tuned policies that execute manipulation tasks on the arm. Full evaluation, quantified results, and failure analysis on the Robot Learning page.
Offline Reinforcement Learning for Vision-Based Manipulation 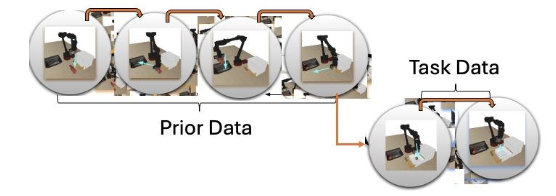
Built an offline RL pipeline (TD3+BC) for vision-based manipulation on the WidowX arm in simulation, on the pick-and-place experimental setup from the COG paper. Replaced the CNN visual encoder with a pretrained ResNet-18 backbone, achieving faster and more stable convergence than a CQL baseline within 200 epochs. (code)
Multimodal Sarcasm Detection (Vision–Language) 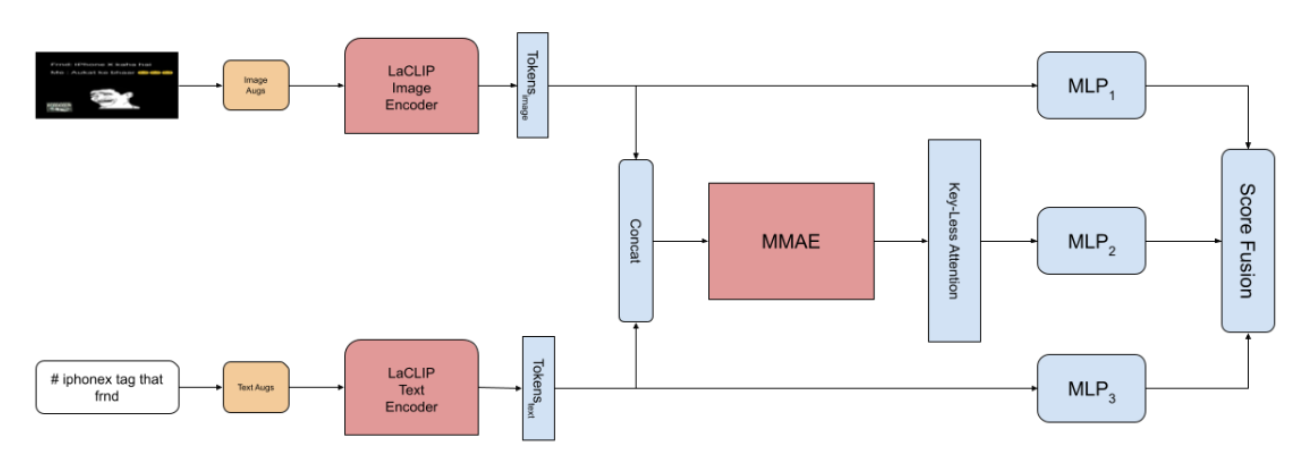
Fine-tuned a Vision Transformer with LaCLIP embeddings on the MMSD 2.0 (image–text pairs) dataset, taking advantage of text-augmented pre-training and to test whether the richer text supervision improves cross-modal reasoning. (code)
publications
Attention Actor-Critic Algorithm for Multi-Agent Constrained Co-operative Reinforcement Learning
AAMAS 2021 (Proceedings of the 20th International Conference on Autonomous Agents and Multiagent Systems), 2021
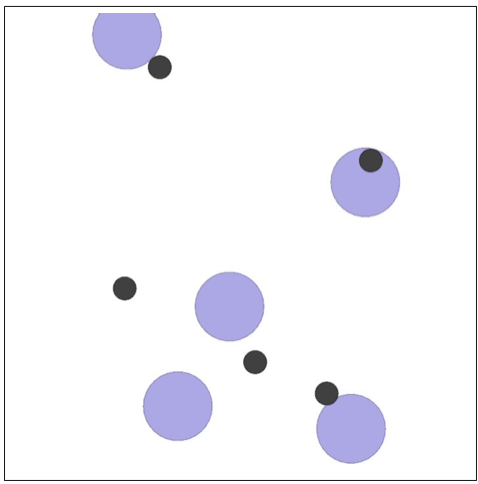
P. Parnika*, Raghuram Bharadwaj Diddigi*, Sai Koti Reddy Danda* and Shalabh Bhatnagar. "Attention Actor-Critic Algorithm for Multi-Agent Constrained Co-operative Reinforcement Learning." AAMAS 2021.
(* denotes equal contribution)
Paper Code
Morphology-Agnostic Reinforcement Learning with BERT
M.Sc. research report, Université de Montréal — REAL Lab, Mila (advisor: Prof. Glen Berseth), 2025
A transformer-based actor-critic architecture with a novel tokenization scheme that trains a single reinforcement-learning policy across multiple robot morphologies, conditioned on BERT-encoded URDF descriptions to generalize to embodiments unseen during training.
talks
Talk 1 on Relevant Topic in Your Field
Published:
This is a description of your talk, which is a markdown file that can be all markdown-ified like any other post. Yay markdown!
Tutorial 1 on Relevant Topic in Your Field
Published:
Talk 2 on Relevant Topic in Your Field
Published:
Conference Proceeding talk 3 on Relevant Topic in Your Field
Published:
This is a description of your conference proceedings talk, note the different field in type. You can put anything in this field.
teaching
Teaching experience 1
Undergraduate course, University 1, Department, 2014
This is a description of a teaching experience. You can use markdown like any other post.
Teaching experience 2
Workshop, University 1, Department, 2015
This is a description of a teaching experience. You can use markdown like any other post.