Imitation Learning on a Physical Robotic Arm (SO-101)
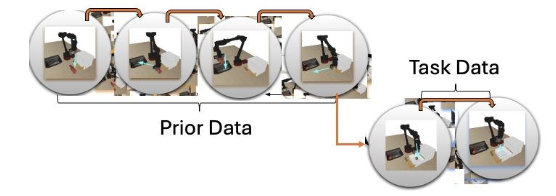
Deployment of imitation-learning policies (ACT, SmolVLA, π0.5) on a SO-101 robotic arm: collected teleoperated demonstrations and fine-tuned policies that execute manipulation tasks on the arm. Full evaluation, quantified results, and failure analysis on the Robot Learning page.